National Robotics LeagueNRL 2026 · HYPERDRIVE

Overdrive009

We are a student robotics team. This is our robot for HYPERDRIVE, and below it the simulator and scouting app we built so every team in the league can practise and scout.

The team

A student team in the National Robotics League 2026.

We build, wire and drive one robot for HYPERDRIVE and write the code it runs. We also wrote the software on this page, and any NRL team can use it.

Team number
009
League
National Robotics League 2026
Game
HYPERDRIVE
Members
10
School
B.D. Somani International School
City
Mumbai

01 · The robot

Four wheels, one arm,a claw for COREs.

Drive
Four-motor skid-steer on 110 mm wheels
Frame
300 × 412 mm bumper frame, 21 mm off the floor
Arm
Servo parallelogram, 145.7 mm links, so the claw stays level
Claw
Two geared fingers that close around a CORE
Power
One 3S pack for all four motors
Control
HexaNRL firmware, 100 Hz loop

Measured on the CAD

Traced from the model the simulator drives.

Every line here comes from our robot's CAD file, in millimetres. Move the arm: the parallelogram keeps the claw level from the floor to straight up.

Side view of the Overdrive 009 robot Traced from the robot CAD, in millimetres. 110 mm wheels on a 145 mm wheelbase, a 300 mm long bumper frame 21 mm off the floor, and a parallelogram arm with 145.7 mm links holding a 95 by 30 mm CORE. STAR pole top 105 HIGH pole top 130 145 wheelbase 300 bumper frame 21 Ø110
52.1°claw centre 171 mm upclears the HIGH pole top
Top view of the Overdrive 009 robot Traced from the robot CAD, in millimetres: a 300 by 412 mm bumper frame, wheels on a 306 mm track. 412 bumper frame 306 track 300
Top view. Front is to the right.

02 · The season

HYPERDRIVE,two and a half minutes.

Two squads, Red and Blue, two robots each. They play on a 12 by 12 foot field of 36 foam tiles. The last 30 seconds are LEVEL UP.

Match
2:30
LEVEL UP
30 s
Field
144 in
Robots
2 v 2

How a match is scored

Rings on poles, a deck to balance.

Robots carry COREs, 95 mm rings, and thread them onto poles or drop them in a zone. Pick a row to find it on the field. Points are from the 2026 game manual.

The HYPERDRIVE field from above A 144 inch square of 36 tiles. Red drives from the top, Blue from the bottom, and the layout is the same for both turned half a circle. Each squad has a start zone, three HIGH poles, two STAR poles, a Space Station with two APEX poles on its wall, a DROP zone, a Source Zone and a vault. RED DRIVER STATIONBLUE DRIVER STATION
Drawn from the field coordinates in our simulator. Blue's half is Red's turned half a circle.
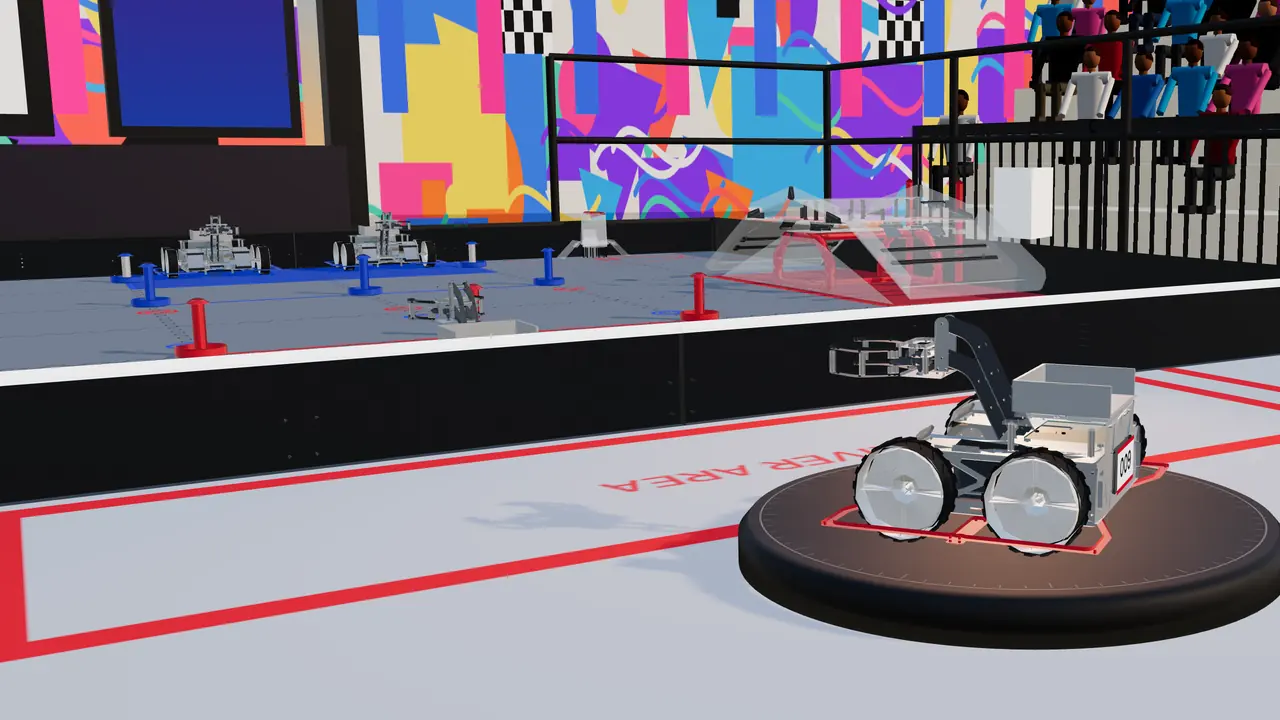
Our simulator's model of the competition venue: two fields, ALPHA and BRAVO, with terraces of spectators and a stage screen.
The venue as modelled in the simulator: two divisions, ALPHA and BRAVO.

03 · What we built

Software for every team in the league.

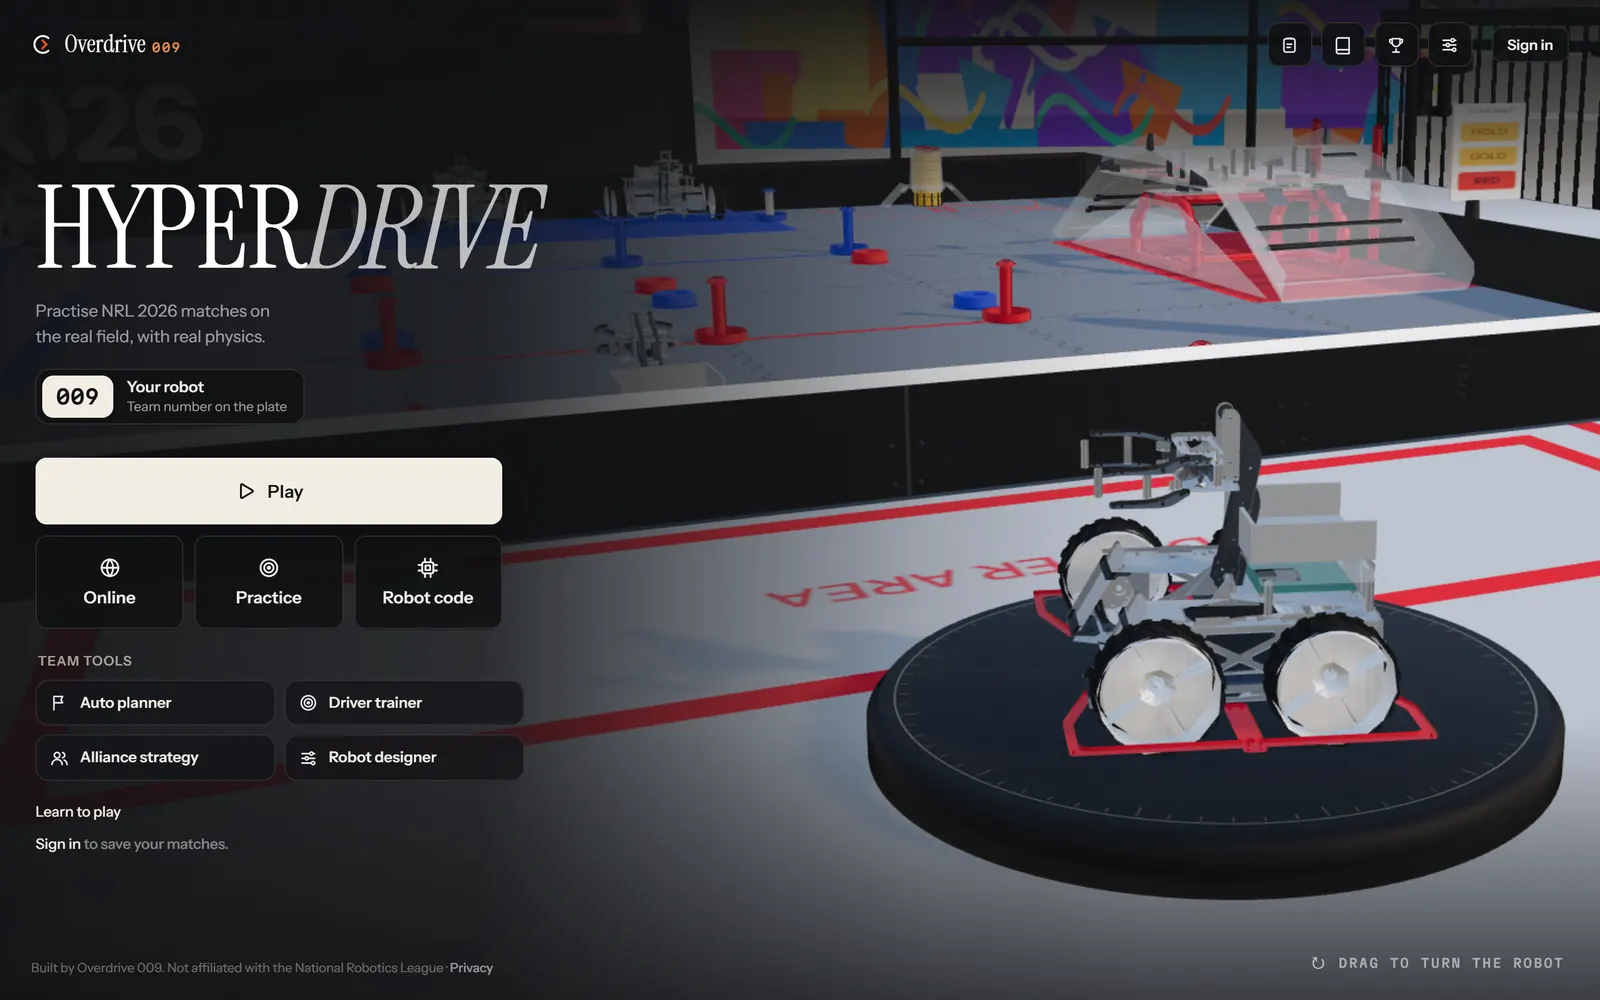
The simulator's home screen: our robot on its plinth beside the field, with Play, Online, Practice, Robot code and the four team tools.

Simulator

Drive the match before the event.

The official field CAD and our robot's CAD, rigid-body physics and live scoring by the 2026 manual. Play alone, with up to four drivers on one computer, or online with each driver on their own laptop.

  • Motors with a torque curve, one battery that sags under load, tyres that grip and slide
  • A Space Station deck that tilts on its pivot
  • Fouls called automatically: pinning, the opponent's zones, de-scoring
Open the simulator
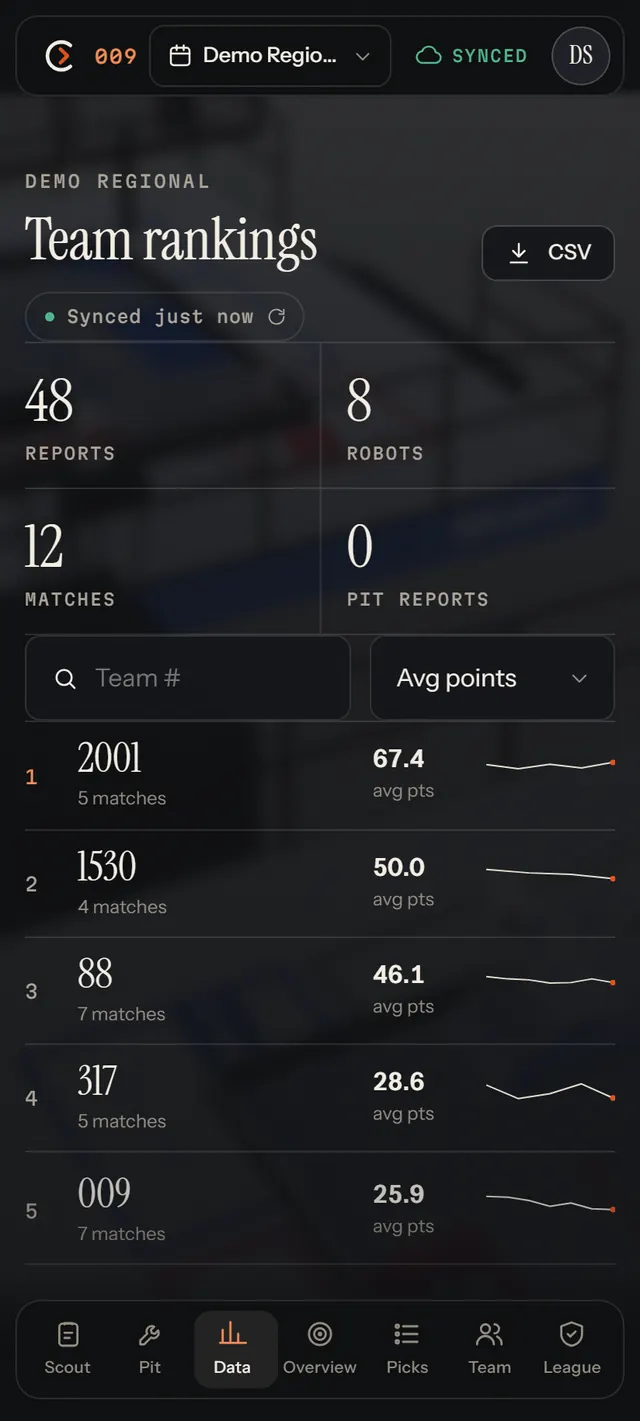
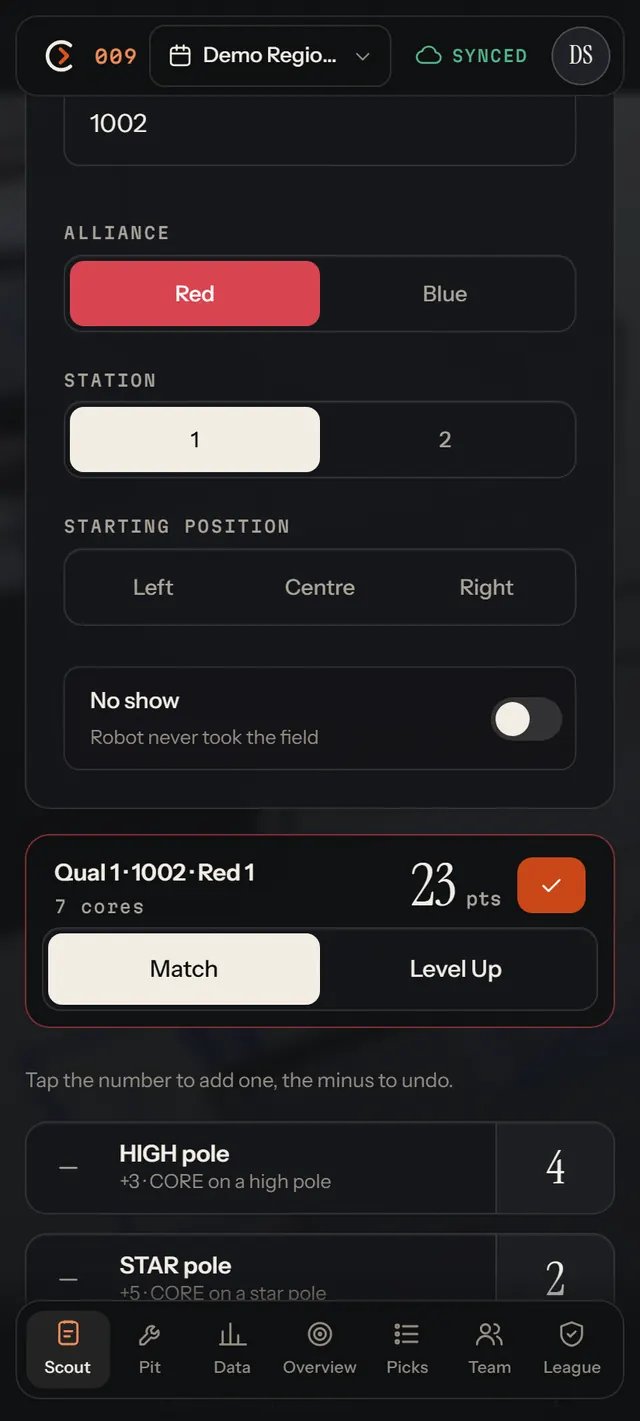
Overdrive Scout's match form on a phone: a 23 point running total and large counters for HIGH and STAR poles. Overdrive Scout's team rankings for a demo event, sorted by average points.

Overdrive Scout

Scouting one thumb can do.

One scout watches one robot. Tap a big counter for each scoring action and the points add up as you go. Reports wait on the phone when the Wi-Fi drops and upload when it is back. Your team sees every scout's reports, ranked.

  • Match and pit reports
  • Team rankings, pick lists, CSV export
  • One account for Scout and the simulator
Start scouting

Screens from Scout's demo event.

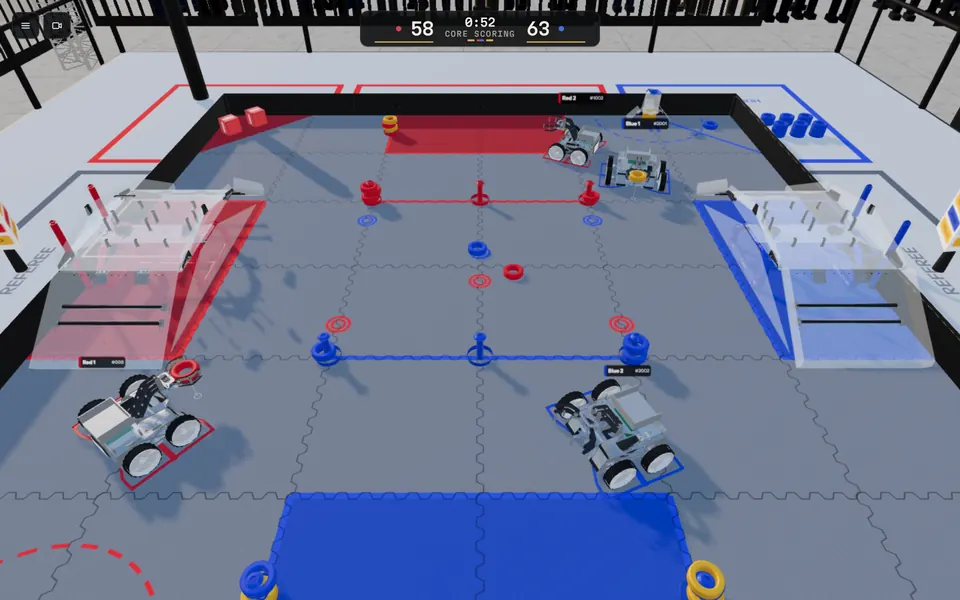
A simulated match with the Champion AI driving all four robots, 58 to 63 with 52 seconds left.

AI drivers

Rookie, Pro and Champion.

They drive with the same controls a person has and keep the same rules. Each plans its path with A* on a 74 by 74 cost grid of the field. In AI-only matches Rookie scores about 45 to 60, Pro about 67 to 69, Champion 100 to 110.

Champion on all four robots, 0:52 left.

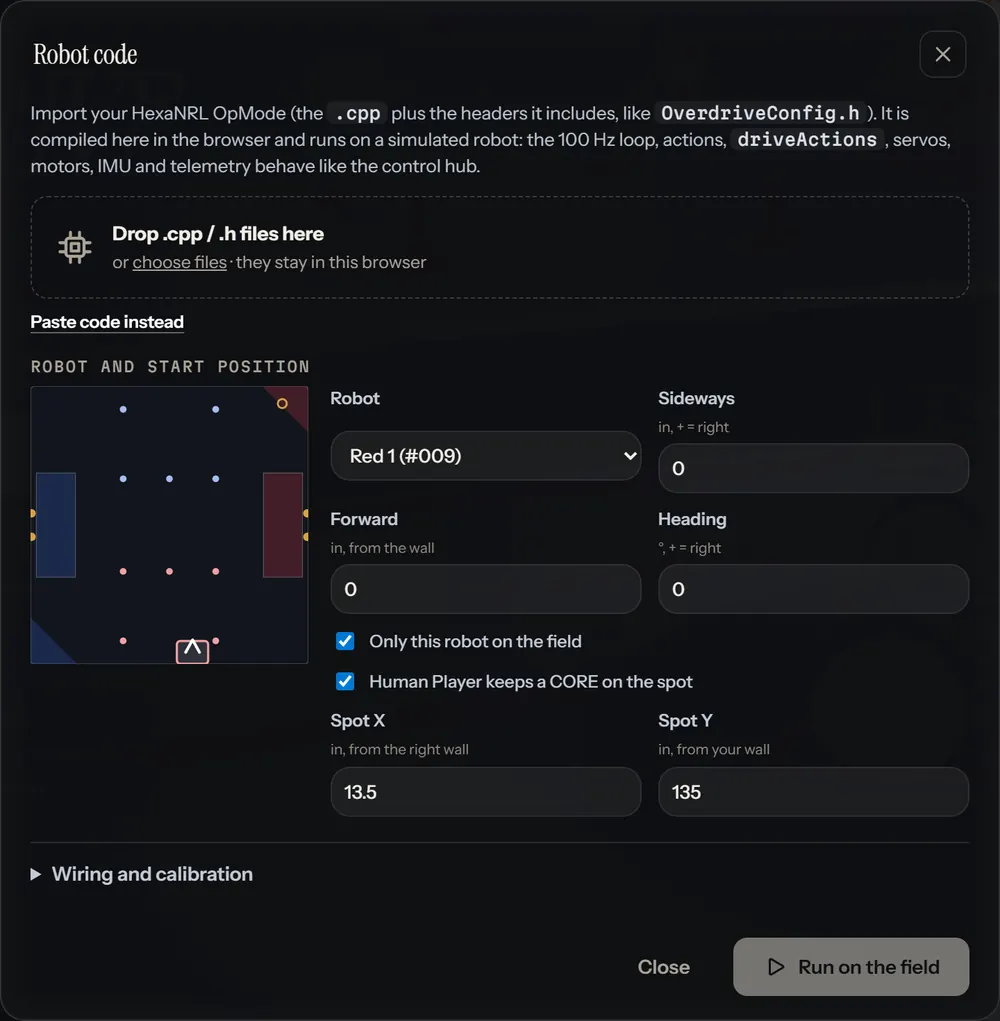
The Robot code dialog: drop .cpp and .h files, choose the robot and its start position.

Robot code

Run your real OpMode.

Drop in your HexaNRL .cpp and the headers it includes. It compiles in the browser and runs on a simulated control hub: the 100 Hz loop, actions, servos, motors, the IMU and telemetry. The files stay in your browser.

Team tools

Four more, inside the simulator.

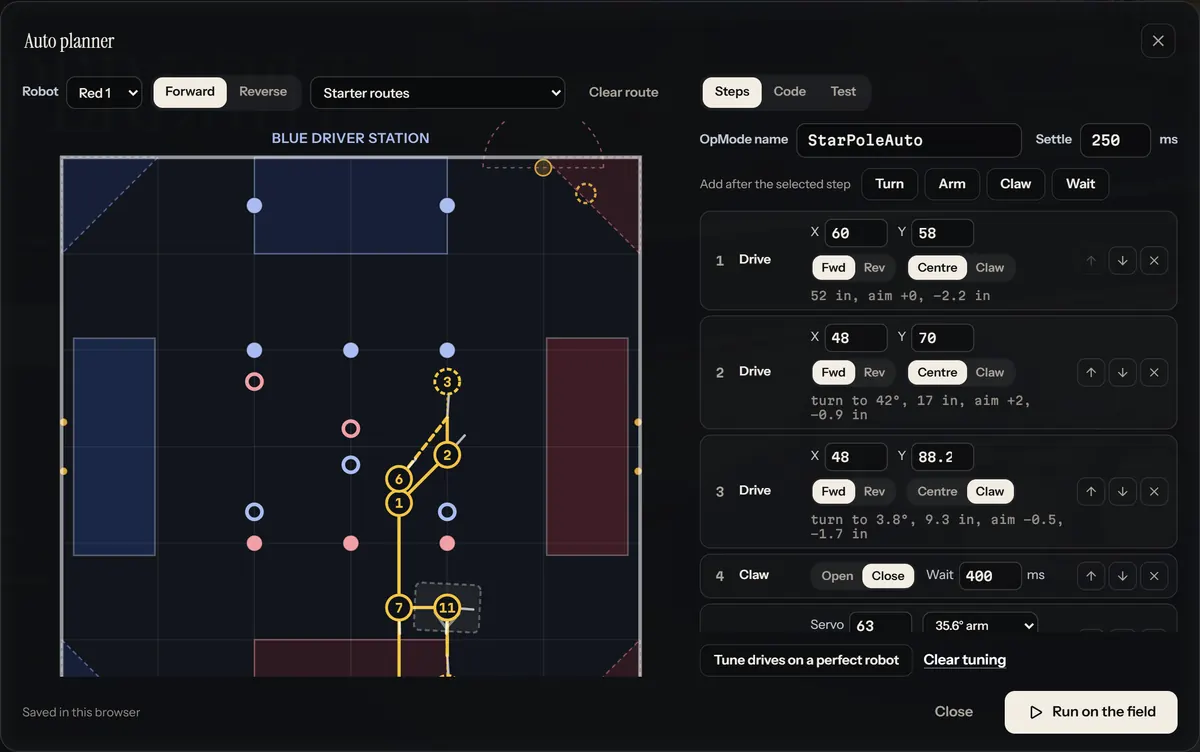
  1. Draw an AUTO route on the field. It writes the HexaNRL OpMode, runs it, tunes the drives on a perfect robot and tests the route on a batch of imperfect ones.

    The Auto planner: a numbered route on the top-down field and the list of drive, turn and claw steps.
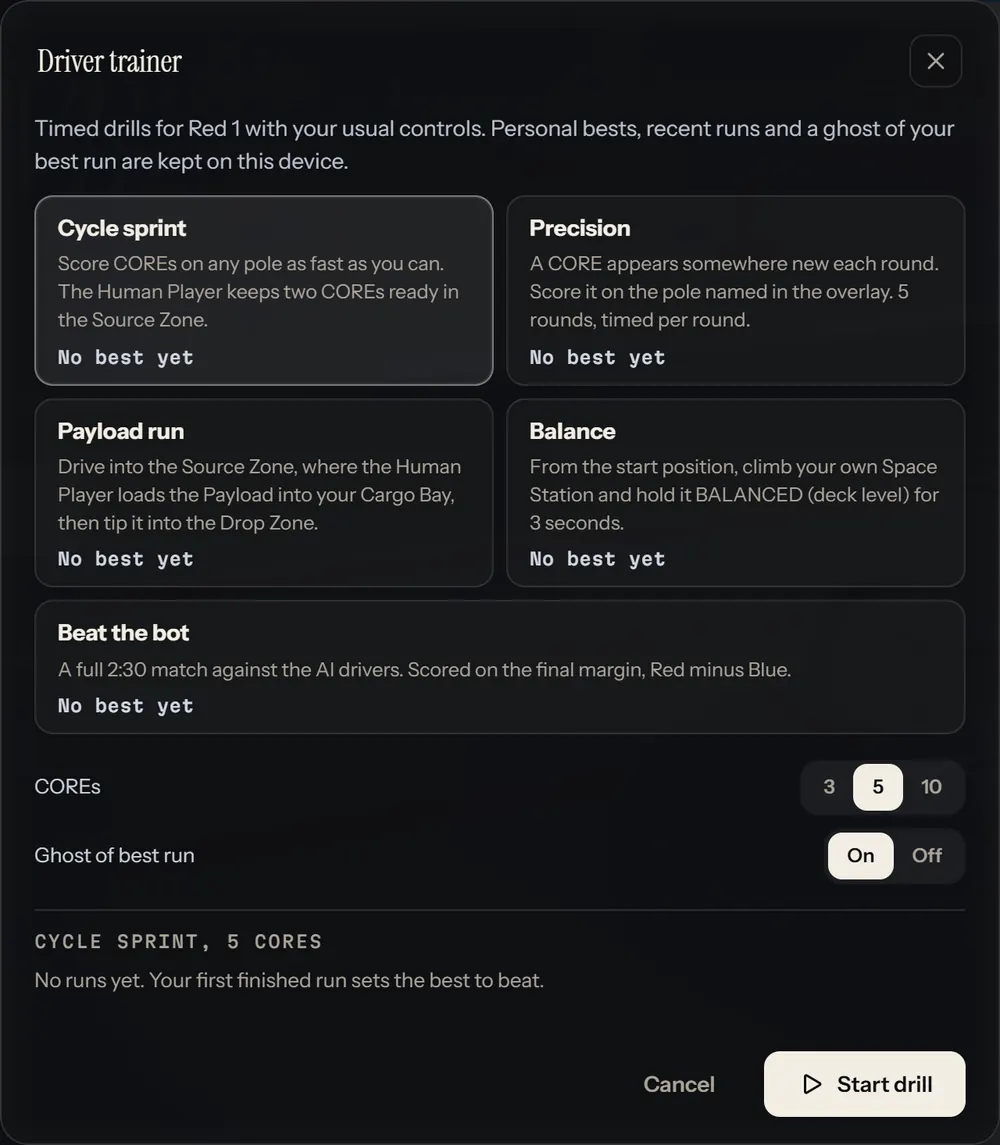
  2. Timed drills on Red 1: cycle sprint, precision, payload run, balance and a full match against the AI. Personal bests, split times and a ghost of your best run.

    The Driver trainer: five drills to pick from, CORE count and ghost settings.
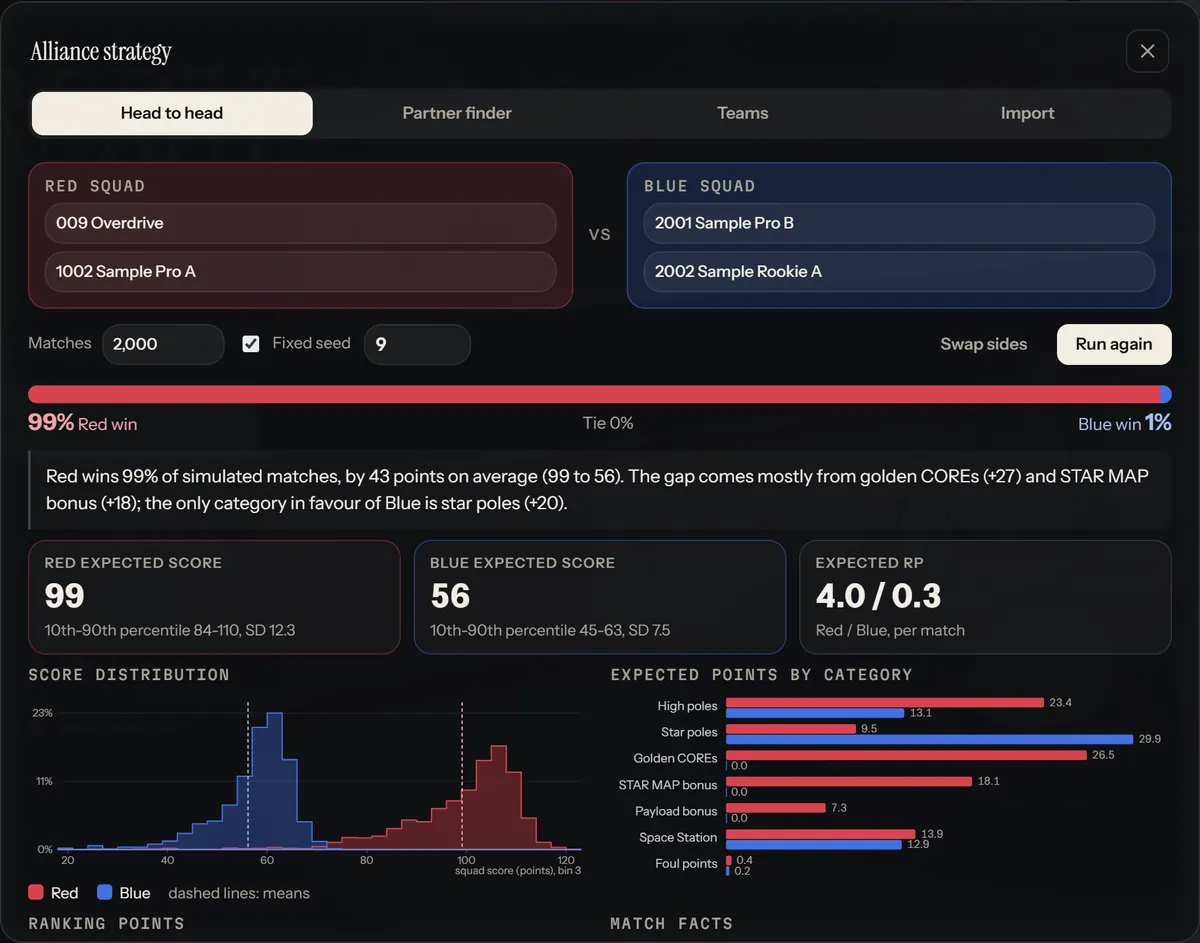
  3. Profiles of what each team can do, from presets or Scout data, and a Monte Carlo match model that scores like the simulator. Head-to-head odds and partner rankings.

    Alliance strategy with sample teams: win odds, expected scores, a score distribution and points by category.
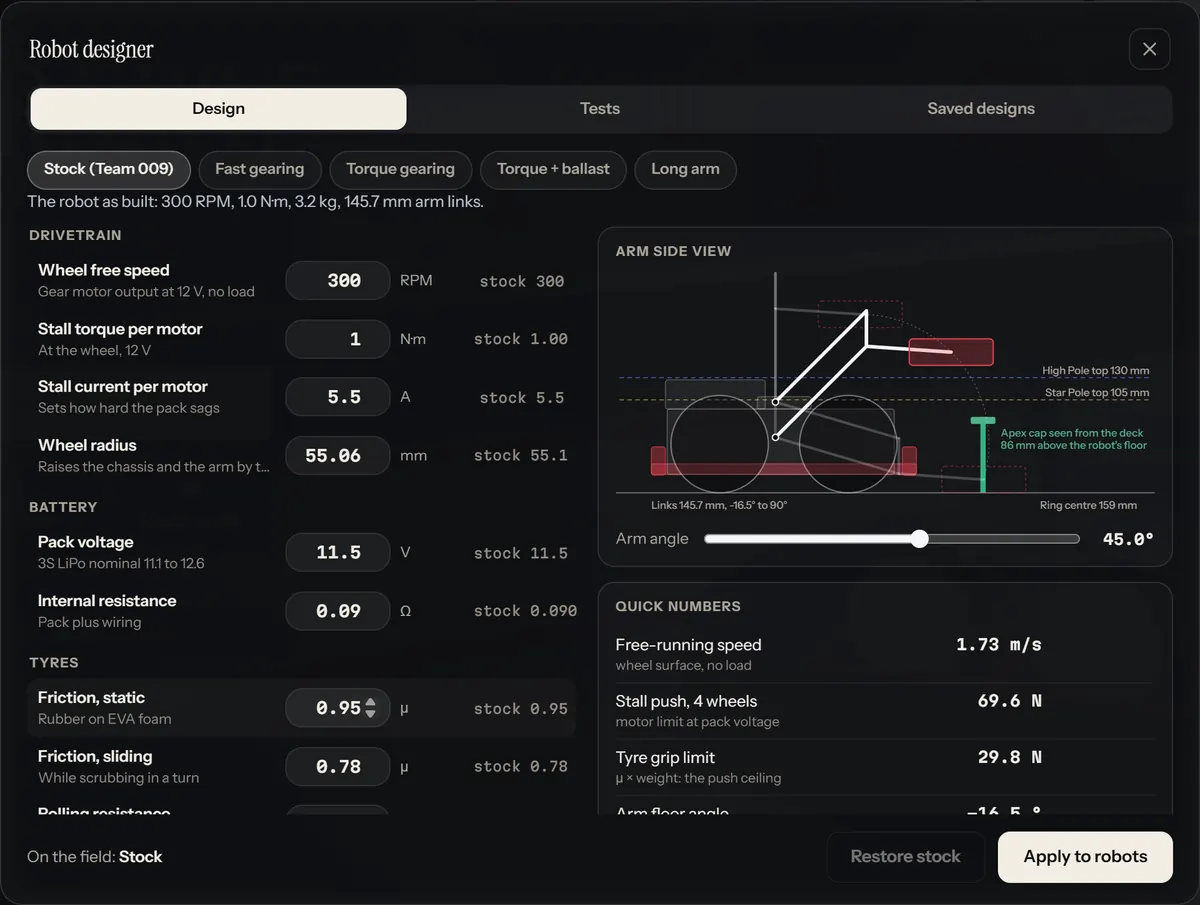
  4. Change the gearing, battery, tyres, mass or arm, put the design on the robots in the simulator, and measure it against the stock robot with a headless test battery.

    The Robot designer: drivetrain and battery settings beside a side view of the arm and its reach.

04 · Changemakers Award project

Viora

A saliva test strip made from purple cabbage and filter paper, read by any phone camera. It tells you if you are dehydrated in thirty seconds, for less than a rupee.

Indicator
Anthocyanin from the cabbage changes colour with pH
Reading
Analysed on the phone. No photos are uploaded.
Evidence
Our first trial was small, one person, and the project site says so.
Visit Viora

05 · Sponsor us

Help us build the next robot.

We are looking for sponsors. Support pays for robot parts, competition fees and travel to events. Write to us and we will tell you what we need.

team@overdrive009.in